The Sysmac Studio Toolbox contains a number of functions and function blocks that you use when programming. You can also create your own as you build up a project.
For Sysmac controllers, we often collect function blocks in libraries so they are easy to distribute. These files have the extension *.slr.
You can create a library yourself in Sysmac Studio. The file with the blocks is saved separately and can be open or closed for viewing (of the code).
Many people at Omron create function blocks, and some of them are collected in a folder under Documents. Many of these have been made without going through strict test routines, so we cannot take responsibility for any problems that may arise if they fail.
Each library is in its own folder, often with documentation and a program example. Some only contain a link for downloading. The folders are sorted by where the blocks were made:
- ATC – made at our technical centre in Barcelona. Usually well documented and tested.
- OECH – made by engineers at Omron Switzerland.
- OEF – made by engineers at Omron France.
- OEN – made by engineers at Omron Norway. Documentation is in the folder, and an outdated, unmaintained short version is in a separate chapter of the Sysmac course compendium.
- OEIT – made by engineers at Omron Italy.
- OEJ – made by engineers at Omron Japan.
- OEUK – made by engineers at Omron UK.
- XR – made by the development department in Japan. Well tested and documented.
Links to the function blocks
| ? Sysmac XR Library downloads | OMRON Industrial Automation | ? Function blocks |
Overview of the contents of some libraries you can download from the links above
Remember to download the manual for each library at the same time.
Some libraries need a free key to work. Contact Support Norway and we'll sort it out.
(We can't keep this overview up to date at all times, so use the links above to get the full picture.)
| Library | Area | Description |
|---|---|---|
| OEN_Datatypes | A collection of general-purpose data types | |
| OEN_BaseBlocks | A large collection of general-purpose functions and function blocks | |
| OEN_CanBus | CAN | General communication over CAN bus with NJ and CJ1W-CORT21, and Eltorque valves in particular |
| OEN_Communication | For Modbus TCP, Modbus RTU, EtherCAT and SMS alarm sending | |
| OEN_Components | KM/K6PM/S8VK | Communication with KM, K6PM and S8VK |
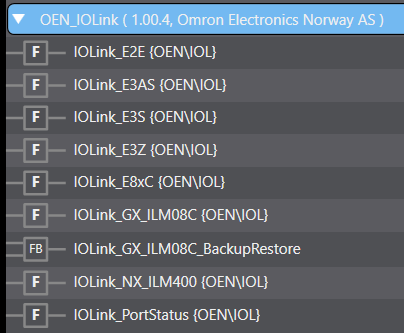
| OEN_IOLink | IO-Link | Communication with E2E, E3AS, E3S, E3Z, E8_C, ILM8C, ILM400 over IO-Link |
| OEN_NJ | NJ | Special variants for NJ. SD card info |
| OEN_Redundancy | Redundancy | Program solution with function blocks for redundancy with NX102 |
| OEN_Acti9_SmartLink | SmartLink | Communication with Schneider's SmartLink system for circuit breakers |
| OEN_API | Tibber | Communication with Tibber's internet API for monitoring power consumption |
| OEN_Drives | M1/MX2/Q2_/SX/TSA | Control of M1, MX2, Q2_, SX and TSA via Modbus and EtherCAT |
| OEN_Servo | Servo | Status and parameters for G5. Matrix functions for trays (picking). EncoderRetain. |
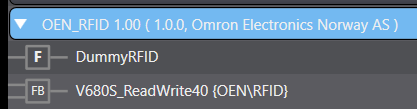
| OEN_RFID | V680 | Communication with V680S RFID reader/writer over EtherNet/IP |
| OEN_NJDeltaRobot | Robot | Control of a G5 servo-driven delta robot with NJ |
| OEN_Robot | Delta/AnyFeeder/TM UR | Communication with delta robot (EIP), AnyFeeder (RS232), TM cobot (Modbus TCP) and UR cobot (EIP) |
| ATC_Ethercat Extended Functions | EtherCAT | Many functions for handling EtherCAT communication |
| ATC_MemoryStack | Data storage | FIFO stack for large amounts of data (4 MB) and storage to SD |
| ATC_Geometry | Robot | Transformations, vectors and points in 2D and 3D |
| ATC_Matrix | Matrix operations | |
| ATC MQTT and JSON | MQTT | Communication via MQTT and encoding/decoding of data in JSON format |
| ATC Serial Comms | NX-CIF | Host Link, FINS and Modbus RTU slave. Can also be used with a CIF mounted on NX-EIC |
| ATC Solar Position | Calculates the sun's position in the sky | |
| ATC Statistical Functions | Statistical functions | |
| ATC Energy Meter | KM-N2, KM-N3 | Communicates with KM via Modbus |
| ATC TLS Mail Send | Send secure email from the CPU | |
| ATC Waveform Analysis | Analysis tools for logged data | |
| ATC_ExtendedCIPServices | Ethernet/IP | Extra functions for EtherNet/IP |
| ATC 1S Positioning | 1S | Positioning with 1S servo without using standard motion commands |
| ATC 1S Monitoring | 1S | Perform 1S data monitoring from 1SN/1SA using EtherCAT, for maintenance and supervision. |
| ATC RK SyncRotary | Servo | Master and slave servo axes for synchronised marking and cutting on the fly |
| ATC PathControl | G5 | 3D motion with G5 servo. Typical for CNC machines |
| ATC Poly7 Trajectory | Servo | Smooth 7th-order polynomial profile for servo axes |
| ATC RaceTrack Shuttle | Servo | Servo control of up to 4 shuttle tracks with a shared "track" |
| ATC Traverse Winding | Servo | Servo control of traverse and spool |
| ATC PackML | PackML | State machine, OEE and data types for standardising packaging machines |
| ATC Mobile PostgreSQL | Mobile robot | Control of mobile robots with PostgreSQL |
| ATC Mobile Robot | Mobile robot | Control of mobile robots with ARCL |
| ATC NJ DeltaRobot | DeltaRobot | Control of a G5 servo-driven delta robot with NJ |
| ATC_TMRobot | TM | Control of TM cobot via Ethernet |
| ATC TMRobot Math Functions | TM | Useful transformation functions for controlling a TM cobot |
| ATC TMRobot_EthernetIP | TM | Communication with TM cobot via EtherNet/IP |
| ATC TMRobot_Modbus | TM | Communication with TM cobot via Modbus TCP |
| ATC_FH_FHV7 EtherCAT | FH | Communication with FH via EtherCAT |
| ATC_OCR | ID40/MV40 | Communication with ID40 and MV40 via EtherNet/IP |
| OCR V640 | V640-HAM11 | Communication with V640 ID system over Ethernet and serial |
| OEJ TMRobot-NX Modbus Communication | TM | Communication with TM cobot via Modbus TCP |
| OCH 1S Handling | 1S | Tools for 1S servo |
| OEF MX2_ControlECat | MX2 | Control of MX2 drive via EtherCAT |
| OEF_FINS NX | FINS | Reading and writing data from/to other CPUs via the FINS protocol |
| OEF MailSend | Send unencrypted email from the CPU | |
| OEF NJ_Status | NJ | Read network/motion status on NJ and show the result as an IAG on the NA panel |
| OEF Webserver NJ NX | Webserver | Create a simple web server in NJ/NX |
| OEF ModbusRTU_Slave NXCIF | Modbus | Create a Modbus RTU slave with NX1W-CIF or NX-CIF |
| OEF ModbusTCP IAG | Modbus | An IAG on the NA panel that can act as a Modbus TCP client and communicate with a Modbus server |
| OEF MRTU_NJ_Master | Modbus | Modbus RTU master with CJ1W-SCU42 and NJ |
| OEF MTCP_Client_NJ | Modbus | Modbus TCP client for NJ |
| OEF MX2_Control_Serial | MX2 | Modbus RTU master for MX2 drives with NX1W-CIF or NX-CIF |
| OEF FQ Vision | FQ2 | Communication with FQ2 vision via EtherNet/IP |
| OEN_OEF MTCP_NJNX Modbus | Modbus | Modbus TCP client and server |
| OEIT 1S G5 Homing | G5/1S | Different types of homing for G5 and 1S servo |
| OEIT Base64Encoder | HTTP | Calculate Base64 when using GET and POST |
| OEIT HTTP | HTTP | HTTP GET and POST |
| OEIT HTTPS | HTTP | HTTP GET and POST with TLS |
| OEUK TMRobot Modbus | TM | Communication with TM cobot via EtherNet/IP |
| OEUK IO-Link Devices | IO-Link | Communication with E2E, E3AS, E3S, E3Z, E8PC, SMC D-MP over IO-Link, with matching IAGs you can use in NA. |
| V275 NJ_NX REST API | V275 | Communication with V275 label printer |
| XR001 MC Test Run | G5 | Filter function for manual jogging of G5 with a handwheel |
| XR002 MC Command Table | G5 | Running a G5 servo based on positions in a table |
| XR003 MC Tool Box | MX2 | Tension control with MX2 for winding and feeding |
| XR004 G5 Servo | G5 | Backup and restore of data in G5 servo |
| XR005 EtherCAT N-Smart | E3NW | Backup and restore of data in E3NW-ECT |
| XR006 Vibration Suppression | G5 | Vibration filter for G5 servo |
| XR007 Temperature Control | Temperature control with digital outputs and analog inputs | |
| XR008 Data Log and Monitor | Data logging and signal monitoring | |
| XR009 Adept Robot Control | Robot | Control of Adept robot via EtherNet/IP |
| XR010 NX-RS Weighing Control | RS1201 | Load cell weighing solution with NX-RS1201 |
| XR011 1S Servo | 1S | Backup and restore of data in 1S servo |
| XR012 PackML | PackML | Control of spool and knife for cutting in packaging machines |
| XR013 Servo Press | 1S | Control of a press with 1S servo and load cell |
| XR014 ZW Dimension Measurement | E9NC/ZW | Distance and dimension measurement with E9NC or ZW |
| XR015 Safety System Monitor | Safety | Get Safety SignatureCode and LastModified |
| XR016 NX-HAD | NX-HAD | High-speed logging and limit testing with the NX-HAD analog module |
| XR017 SLMP Communication | Mitsubishi | Communication with Mitsubishi sequencers (iQ-R/Q/L/iQ-F) |
| XR018 Servo and Vision Sensor Feedback Alignment | FH | Servo positioning with FH vision |
| XR019 NX-V680 Communication | V680 | Communication with NX-V680 RFID reader/writer |
| XR020 MQTT Communications | MQTT | MQTT commands and connection to Azure and AWS IoT |
OEN_BaseBlocksIf you install version 5.01 or later, you must also install OEN_DataTypes. 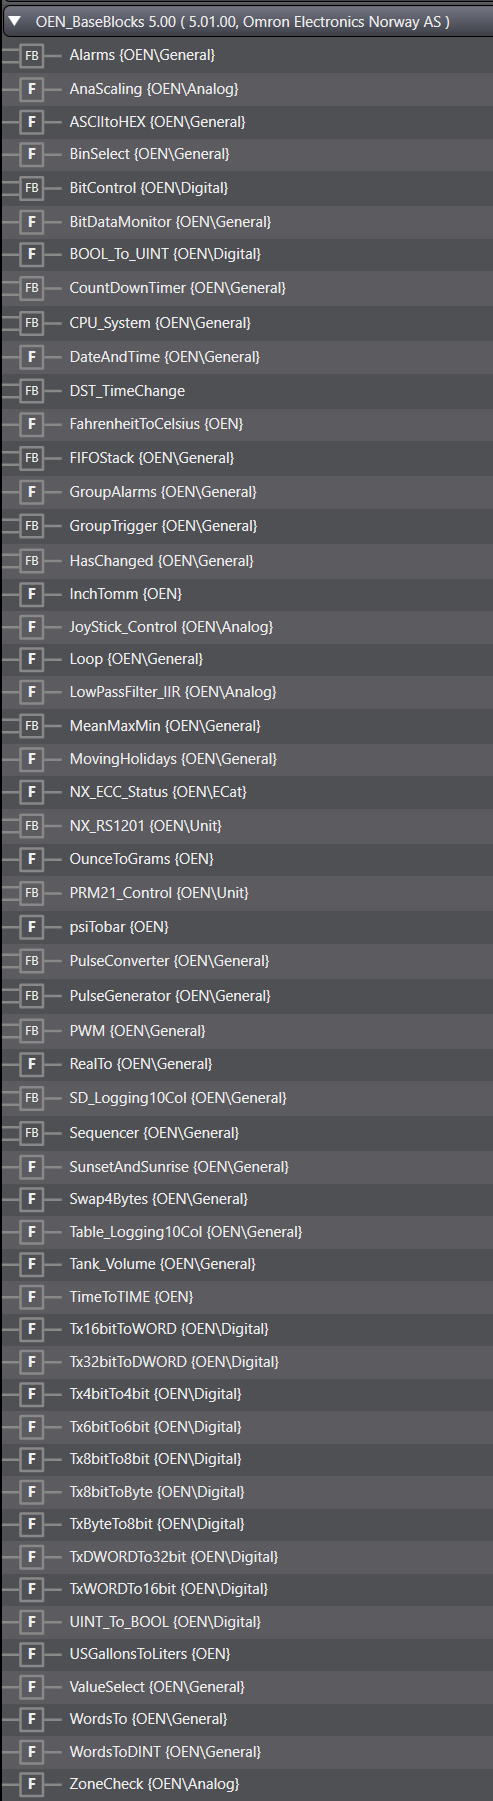 OEN_Components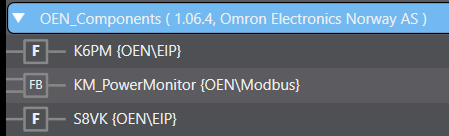 OEN_Drives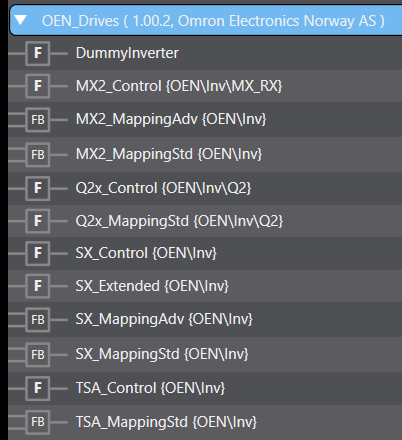 | OEN_Communication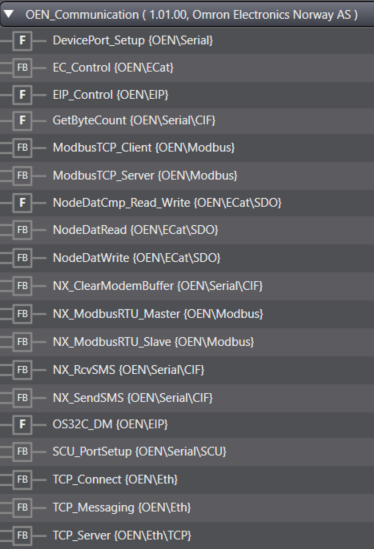 OEN_RFID
OEN_IOLink
OEN_Acti9_SmartLink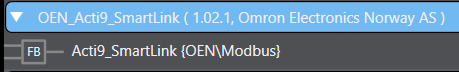 OEN_Servo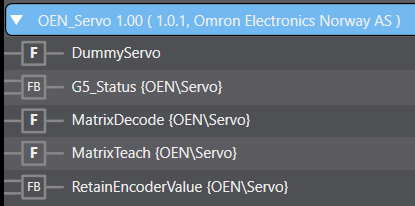 OEN_Robot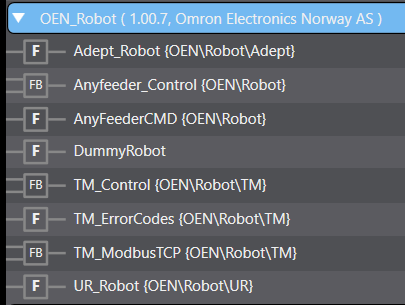 OEN_CanBus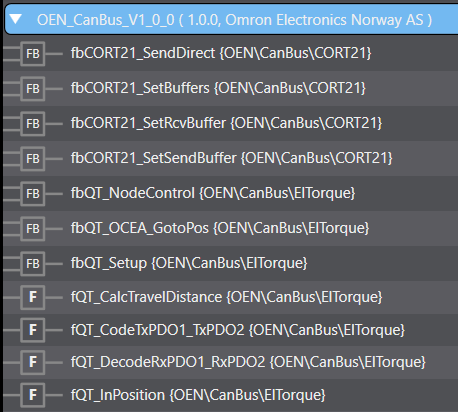 | How to Guide: Serial communication with HS 360X barcode reader How to Guide: Sysmac Modbus TCP How to Guide: MX2 basic PDO mapping on EtherCAT How to Guide: MX2 advanced PDO mapping on EtherCAT How to Guide: MQTT |
ARCL_CommsCommands for mobile robots 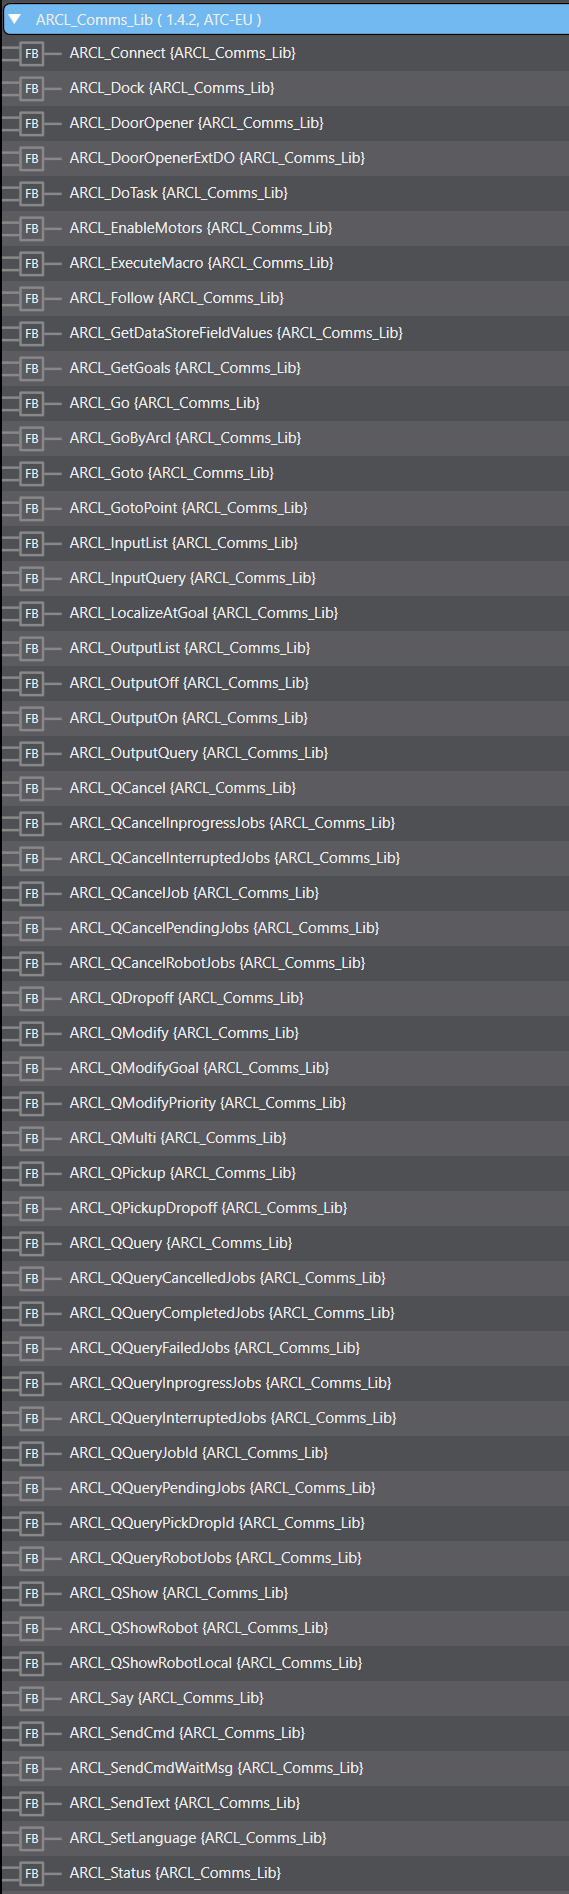  | EthercatExtendedFunctions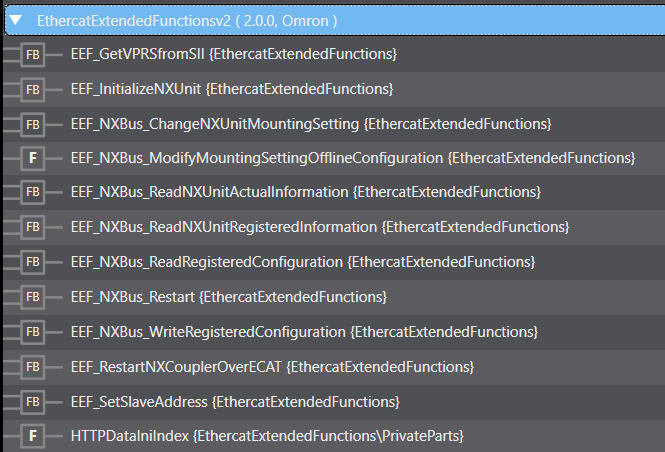 SDOBatch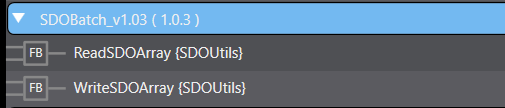 Geometry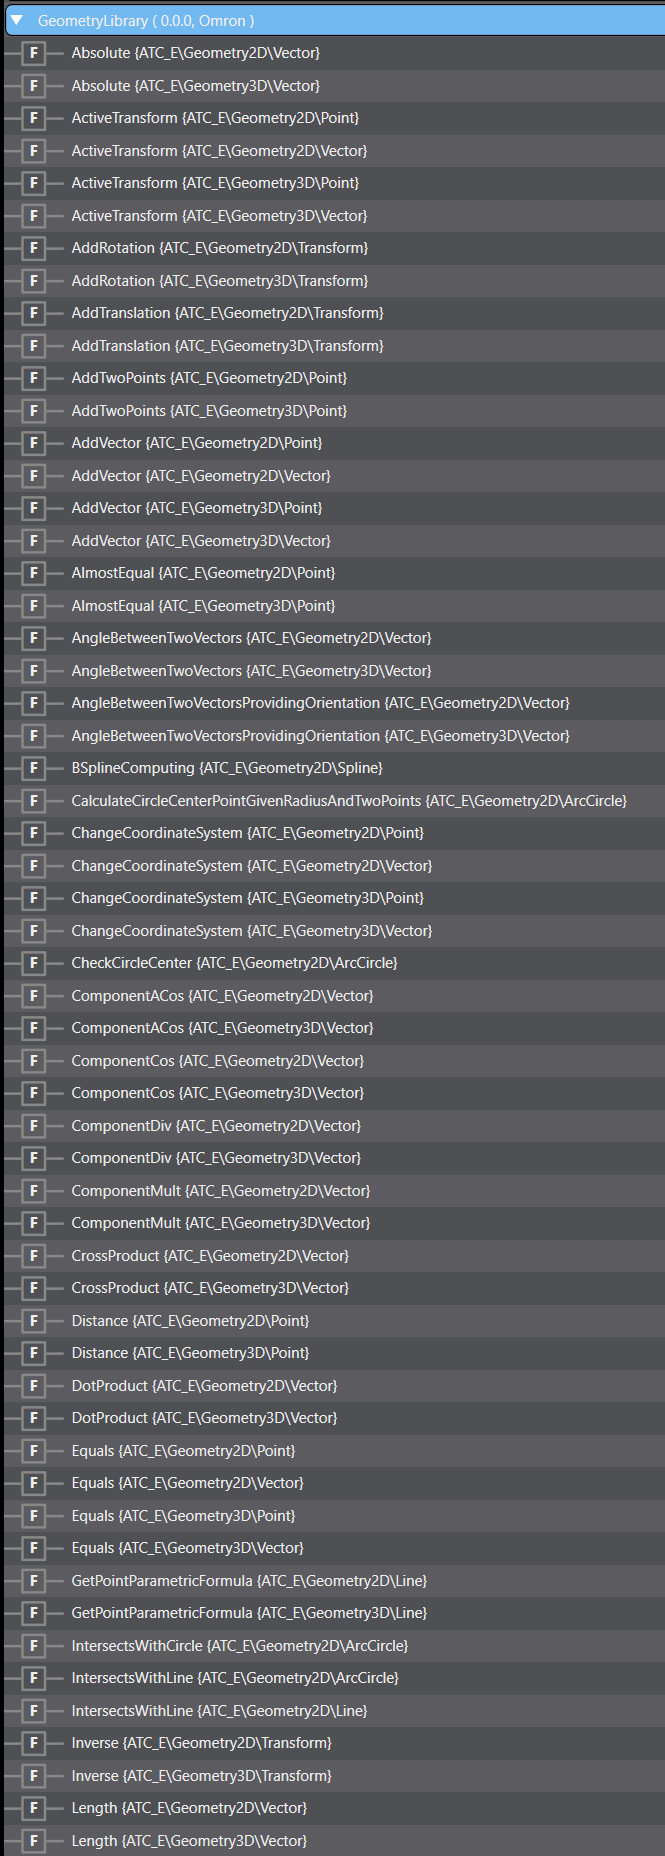 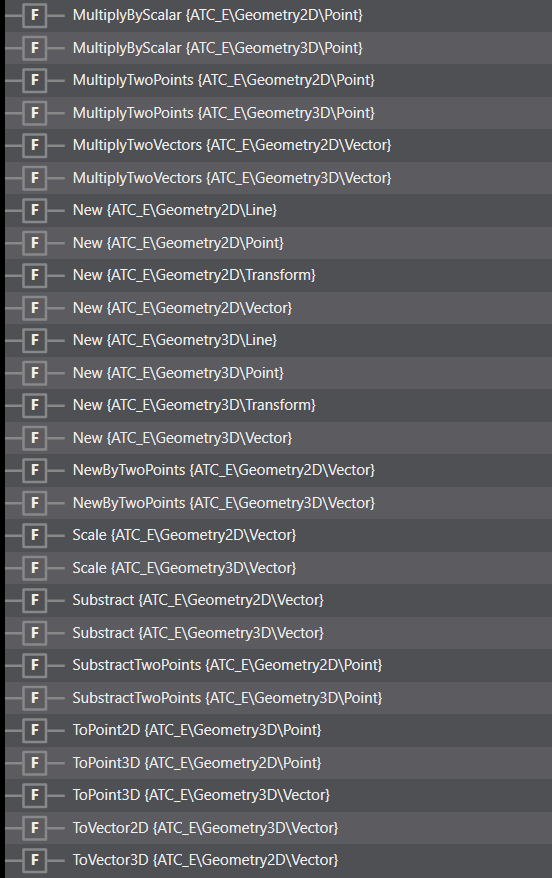 | HTTP Library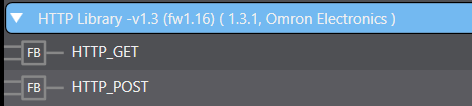 base64_encoder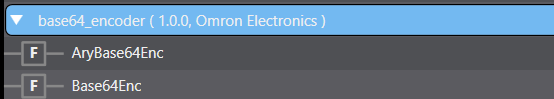 Matrix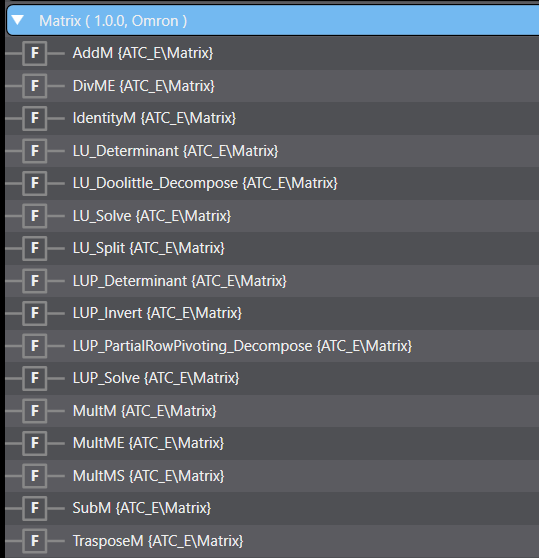 |
Was this article helpful?
That’s Great!
Thank you for your feedback
Sorry! We couldn't be helpful
Thank you for your feedback
Feedback sent
We appreciate your effort and will try to fix the article